Examples
f = figure();
sys = tf([1 2], [1 3 2]);
pzmap(sys);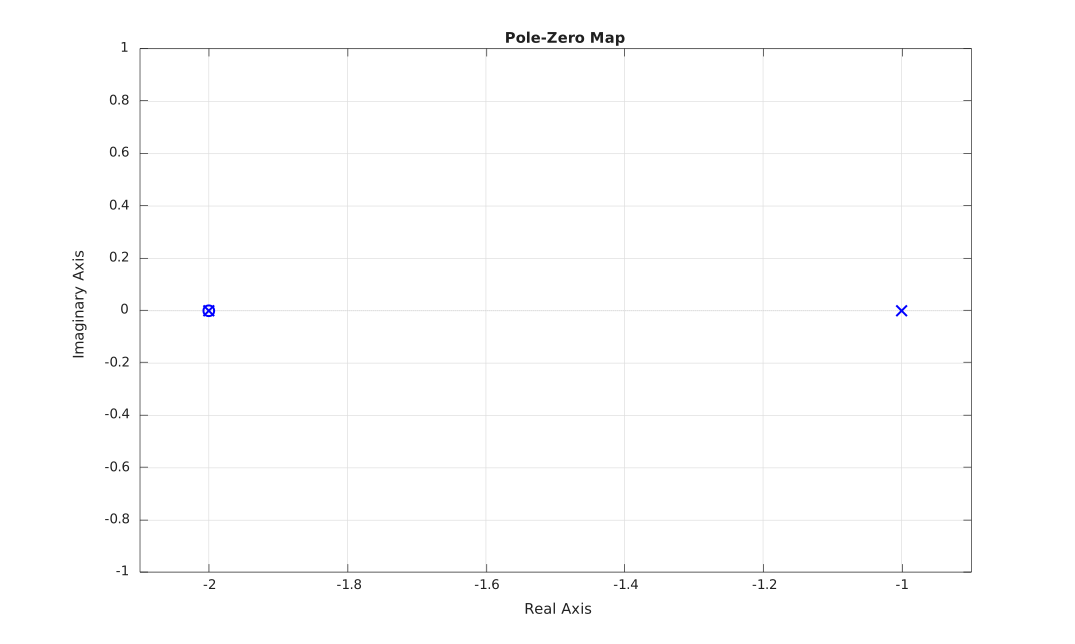
sys = tf([1 2], [1 3 2]);
[p, z] = pzmap(sys)pzmap(sys)
[p, z] = pzmap(sys)
| Parameter | Description |
|---|---|
| sys | Dynamic system: a SISO LTI model. |
| Parameter | Description |
|---|---|
| p | Poles of the system. |
| z | Zeros of the system. |
pzmap(sys) plots the poles and zeros of the dynamic system model sys in the complex plane.
Each pole is marked with an x and each zero with an o.
When output arguments are requested, [p, z] = pzmap(sys) returns the poles p and the zeros z without producing a plot.
f = figure();
sys = tf([1 2], [1 3 2]);
pzmap(sys);sys = tf([1 2], [1 3 2]);
[p, z] = pzmap(sys)| Version | Description |
|---|---|
| 1.0.0 | initial version |